
omnilink-tech / omnisim
An open-source robotics workshop for agents: simulate complete robots on high-fidelity physics, build digital twins, make the parts on CNC, laser and 3D-printer twins, connect simulation to real robots, and let AI agents program, test and debug it all, just by talking to it.
Why this job: topics: reinforcement-learning, synthetic-data
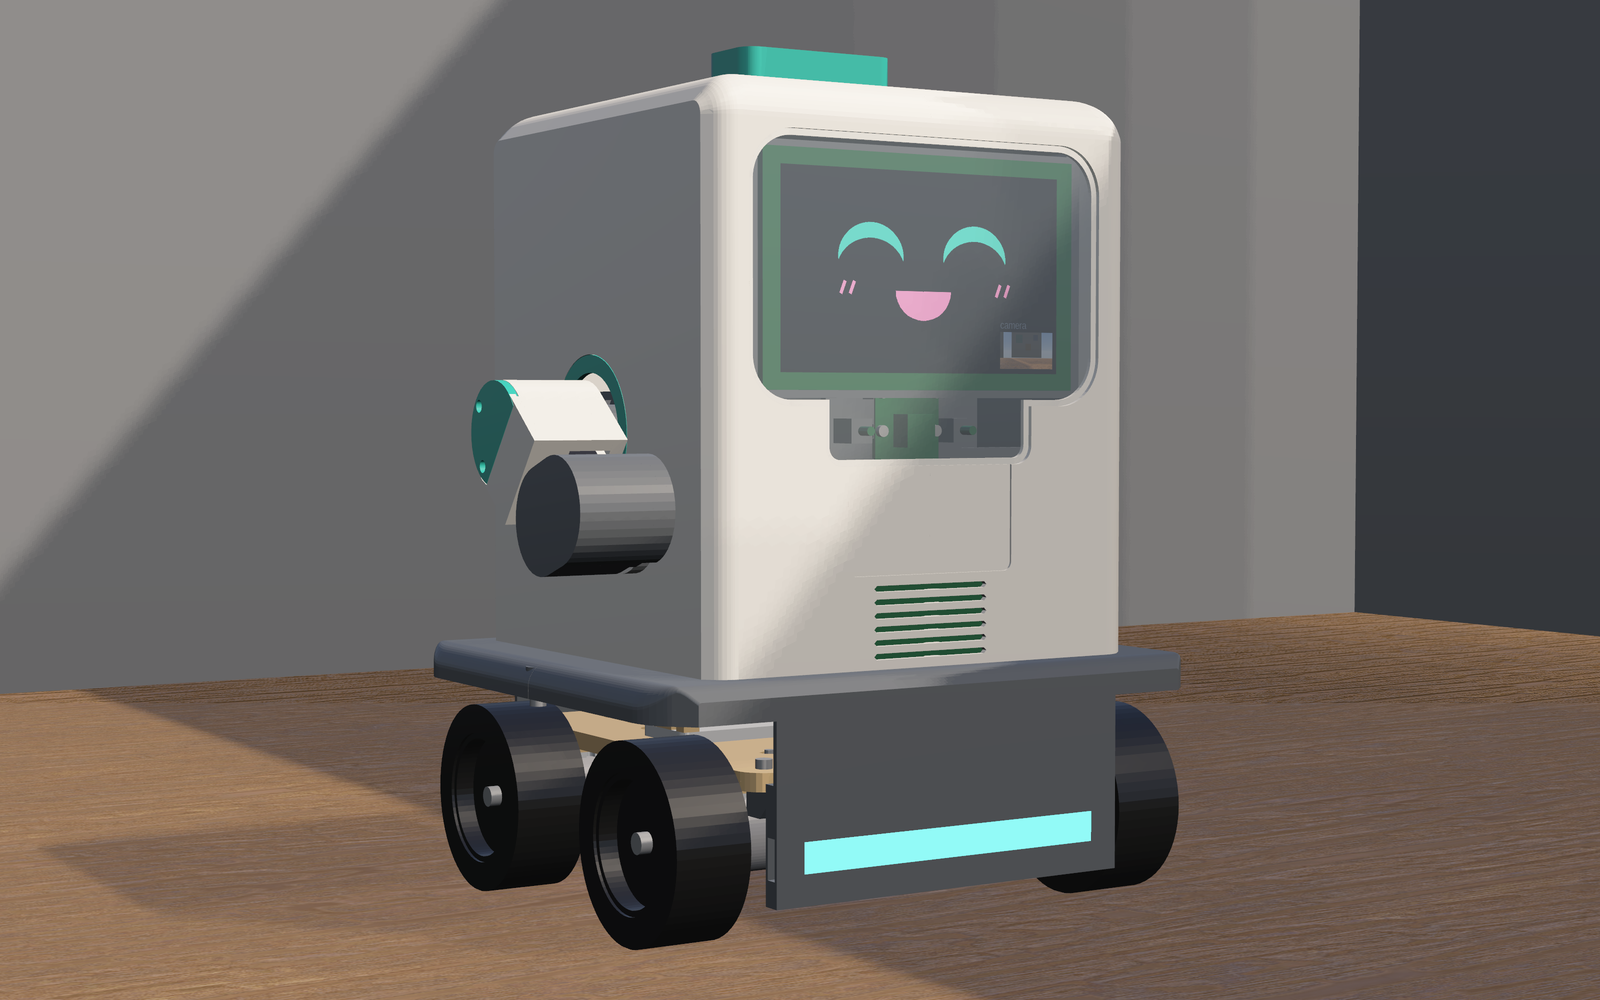
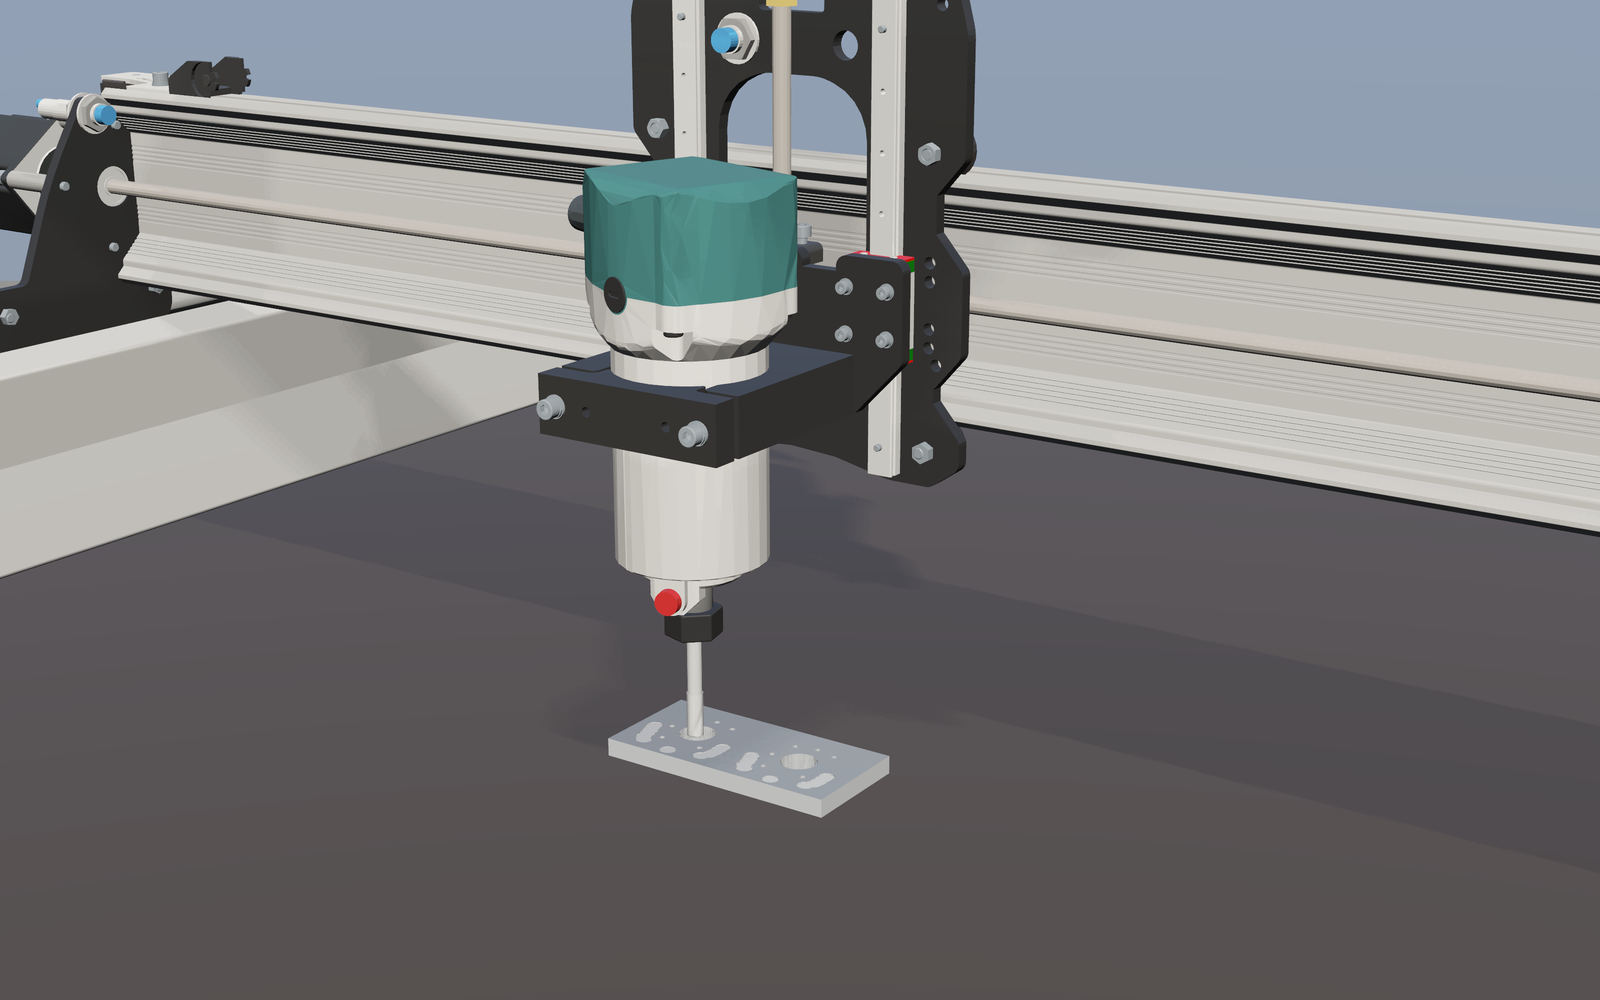
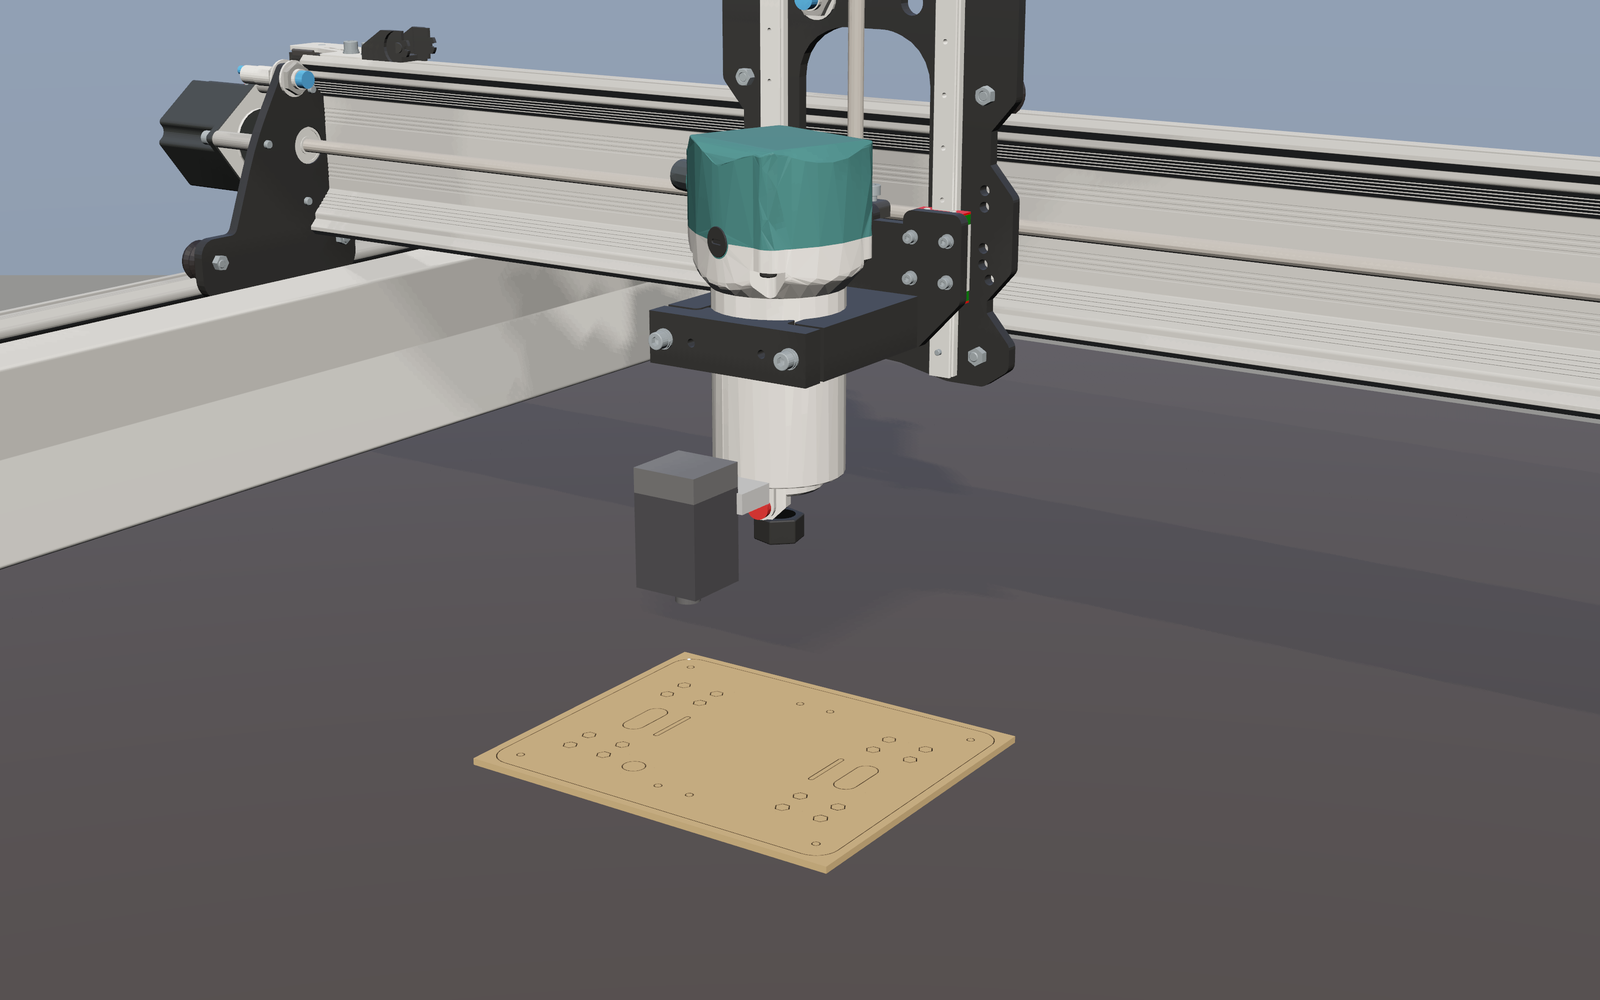
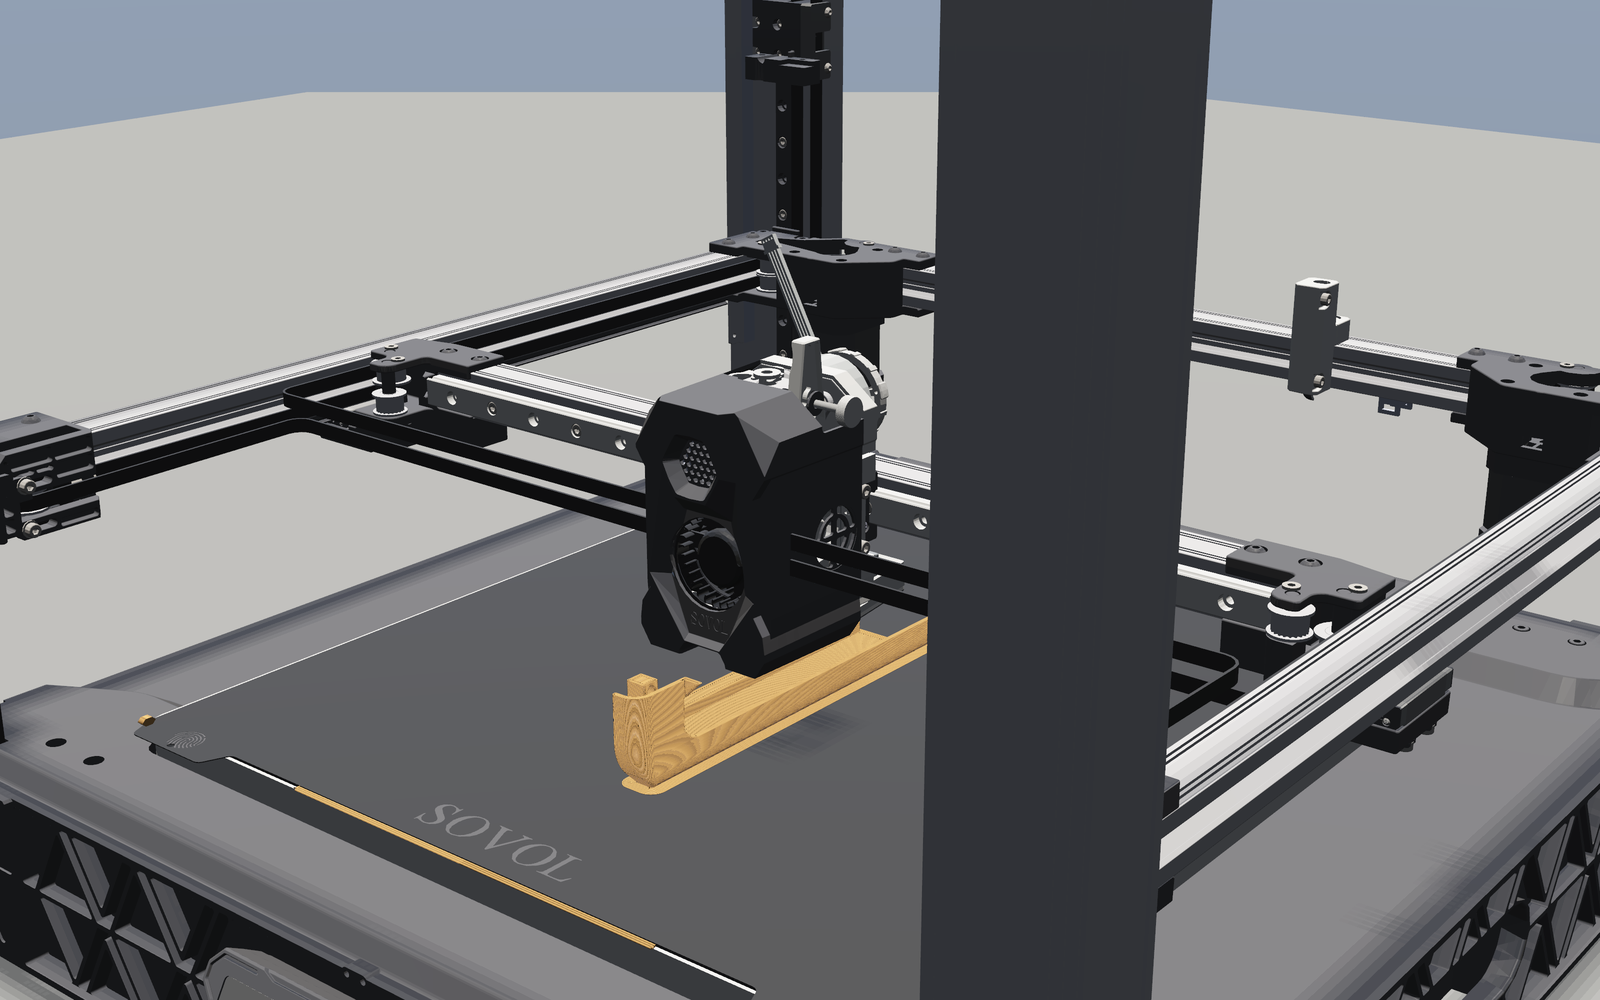
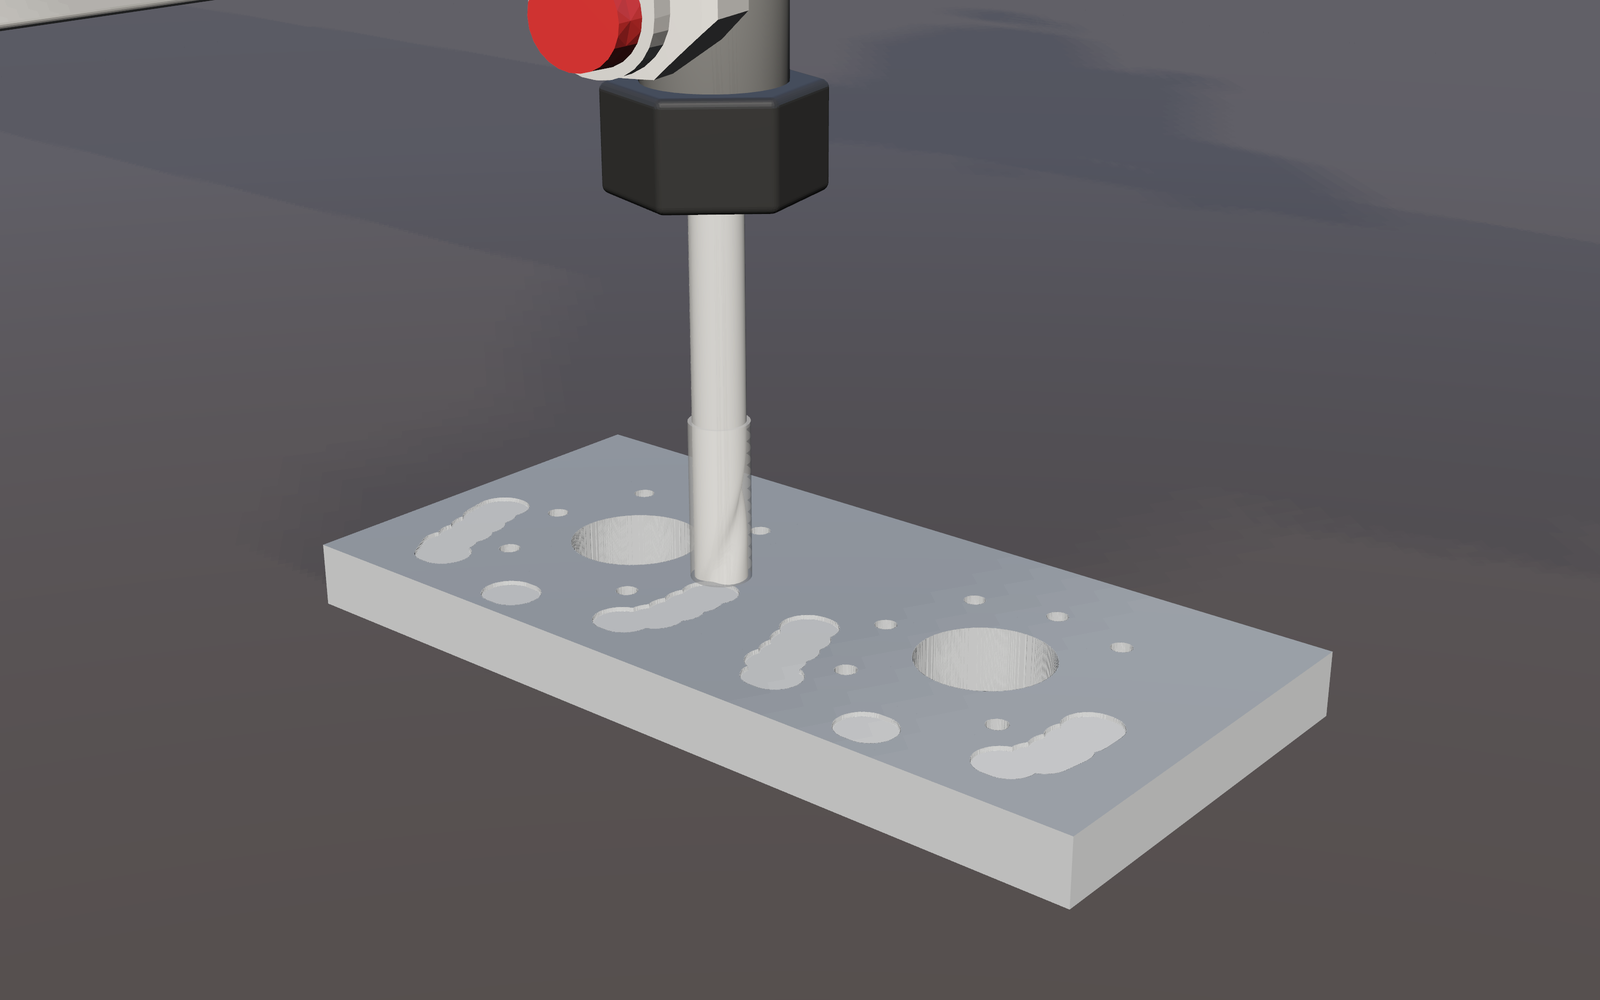
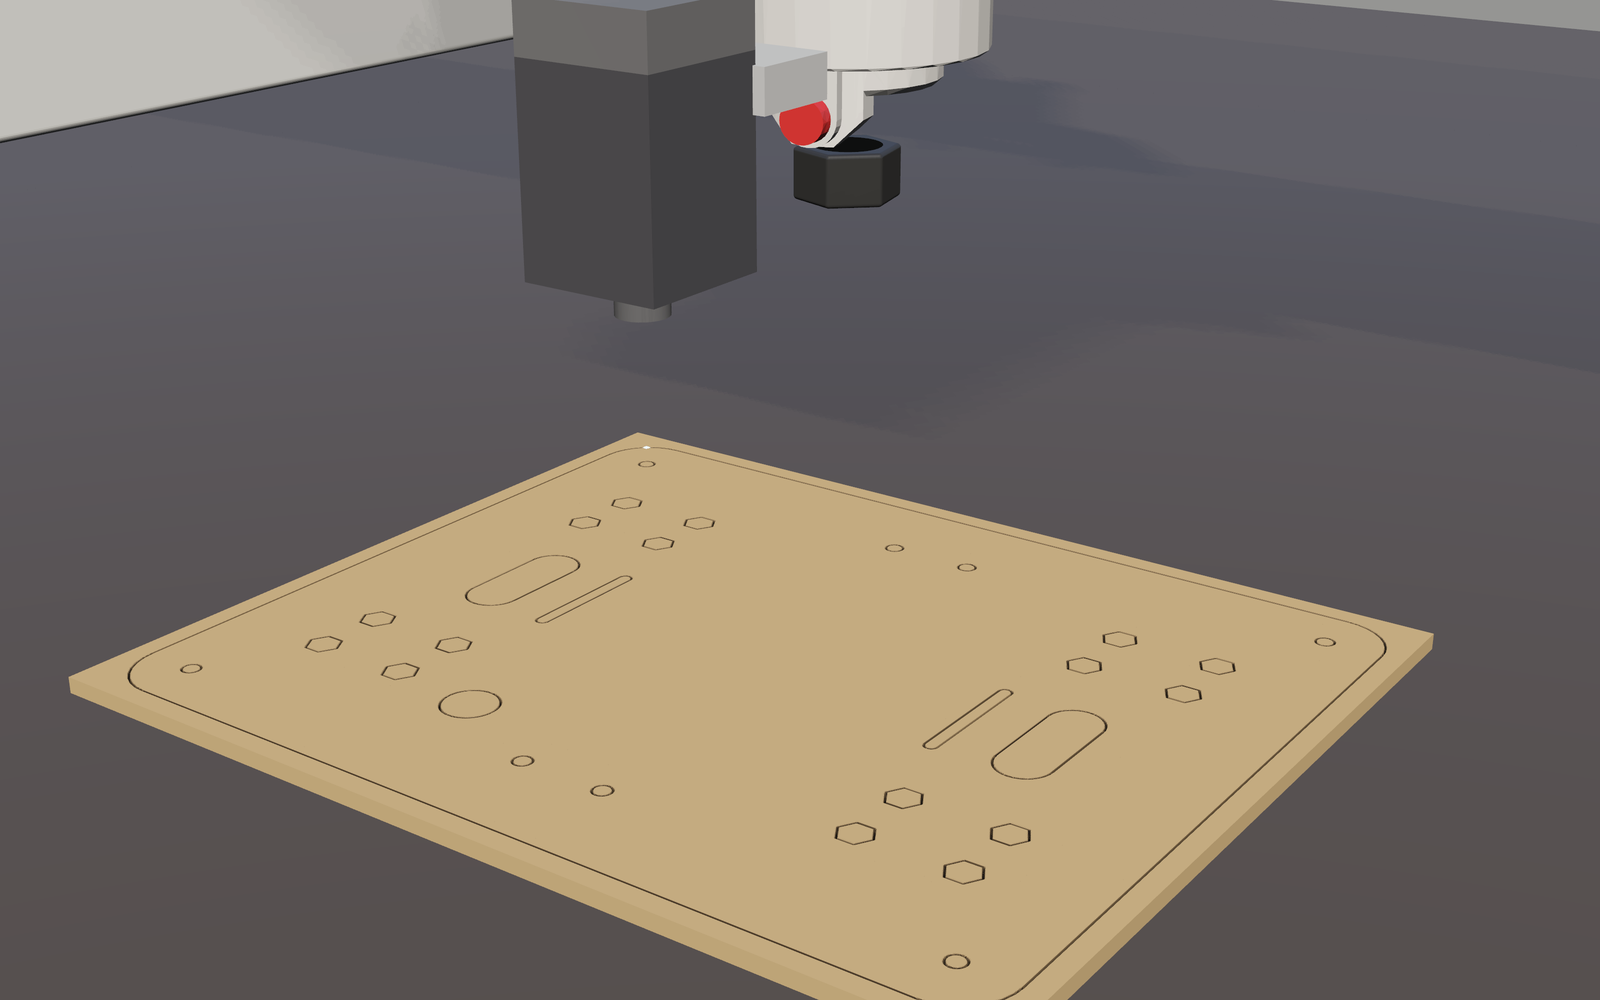
What it does
If you're learning robotics, building a robot, or have an idea but don't have access to the hardware, OmniSim is built for you.
Get started
No single install command. Read the steps in the README (opens in new tab)
- Maintenance
- Active
- Last commit 5 days ago
- Stars
- 192
- +2 this week
- Licence
- Apache-2.0
- Allows business use
- Downloads for
- Windows
- From the latest release
- Latest version
- v10.0.3
- Released 5 days ago
- Built with
- Python
- 61% of the code
Is it looked after?
- Contributors
- 3
- Last 90 days
- Issues
- 100% closed
- 0 still open
- Pull requests
- 5 merged
- 0 waiting
- Releases
- 42
- 30+ in the last year
More: download files, languages, topics and project record
Languages
- Python 61%
- C++ 15%
- G-code 9%
- nesC 6%
Topics
- ai-agents
- mcp
- mujoco
- physics-simulation
- reinforcement-learning
- robot-simulator
- robotics
- ros2
- simulation
- webots
- agentic-ai
- autonomous-agents
Project record
- JobFine-tuning
- StatusListed
- Commits60
- Forks9
- Watching2
- Stars in 28 days+5
- CreatedMay 1, 2026
- First seen by usNov 7, 2026
- CheckedNov 10, 2026