
rokbenko / quackd
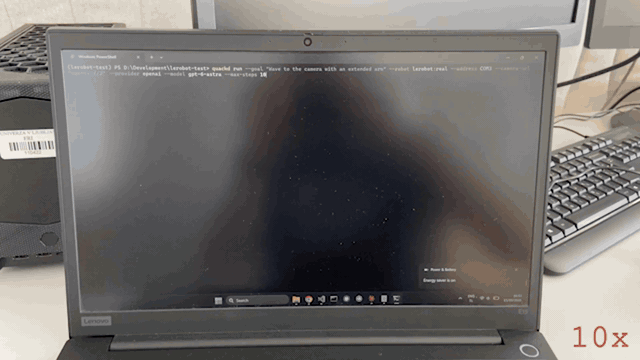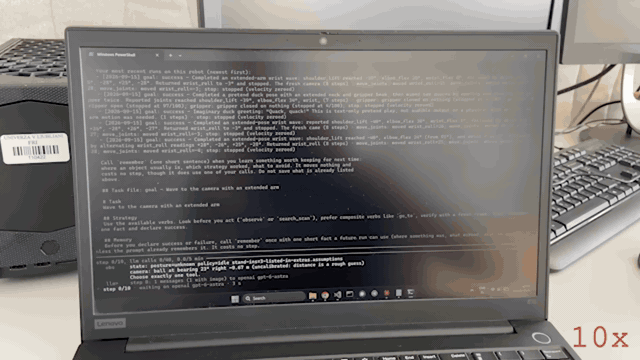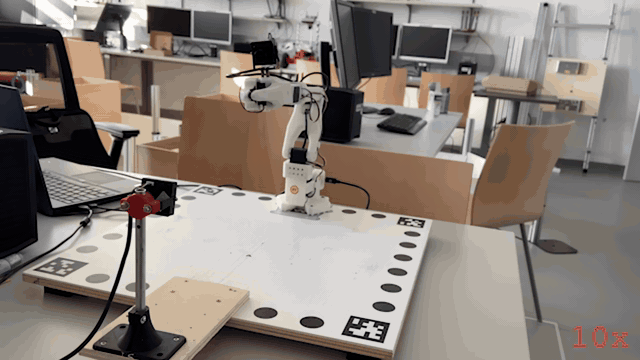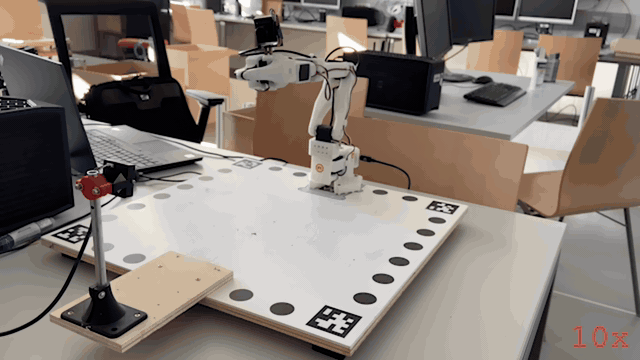
One CLI for all your robots. Connect them, command them, and let them work together, each with an LLM for a brain (Claude, OpenAI, Gemini, Grok, or local via Ollama or vLLM), VLAs for arms and decision LLMs (Jev, Laya, Kev). Drives Microduck, Open Duck Mini, LeRobot, XLeRobot, AlohaMini, ToddlerBot, or any ROS 2 base from a laptop, offboard.
Why this job: topics: ollama, local-llm
Get started
No single install command. Read the steps in the README (opens in new tab)
- Maintenance
- Active
- Last commit yesterday
- Stars
- 292
- +4 this week
- Licence
- Apache-2.0
- Allows business use
- Downloads for
- None listed
- No release files
- Latest version
- v0.33.0
- Released 2 days ago
- Built with
- Python
- 98% of the code
Is it looked after?
- Contributors
- 2
- Last 90 days
- Issues
- 80% closed
- 2 still open
- Pull requests
- 96 merged
- 0 waiting
- Releases
- 44
- 30+ in the last year
More: languages, topics and project record
Languages
- Python 98%
- JavaScript 1%
- CSS <1%
- Shell <1%
Topics
- mcp
- microduck
- physical-ai
- claude
- openai
- local-llm
- lerobot
- ai-agents
- ollama
- ros2
- gemini
- jetson
Project record
- JobLocal LLMs
- StatusListed
- Commits1,435
- Forks30
- Watching3
- Stars in 28 days+34
- CreatedAug 28, 2026
- First seen by usNov 7, 2026
- CheckedNov 9, 2026